Research

I use computer vision and machine learning to understand how people behave in real-world traffic, and to make automated systems safer. Jump to a topic:

Pedestrians around the globe

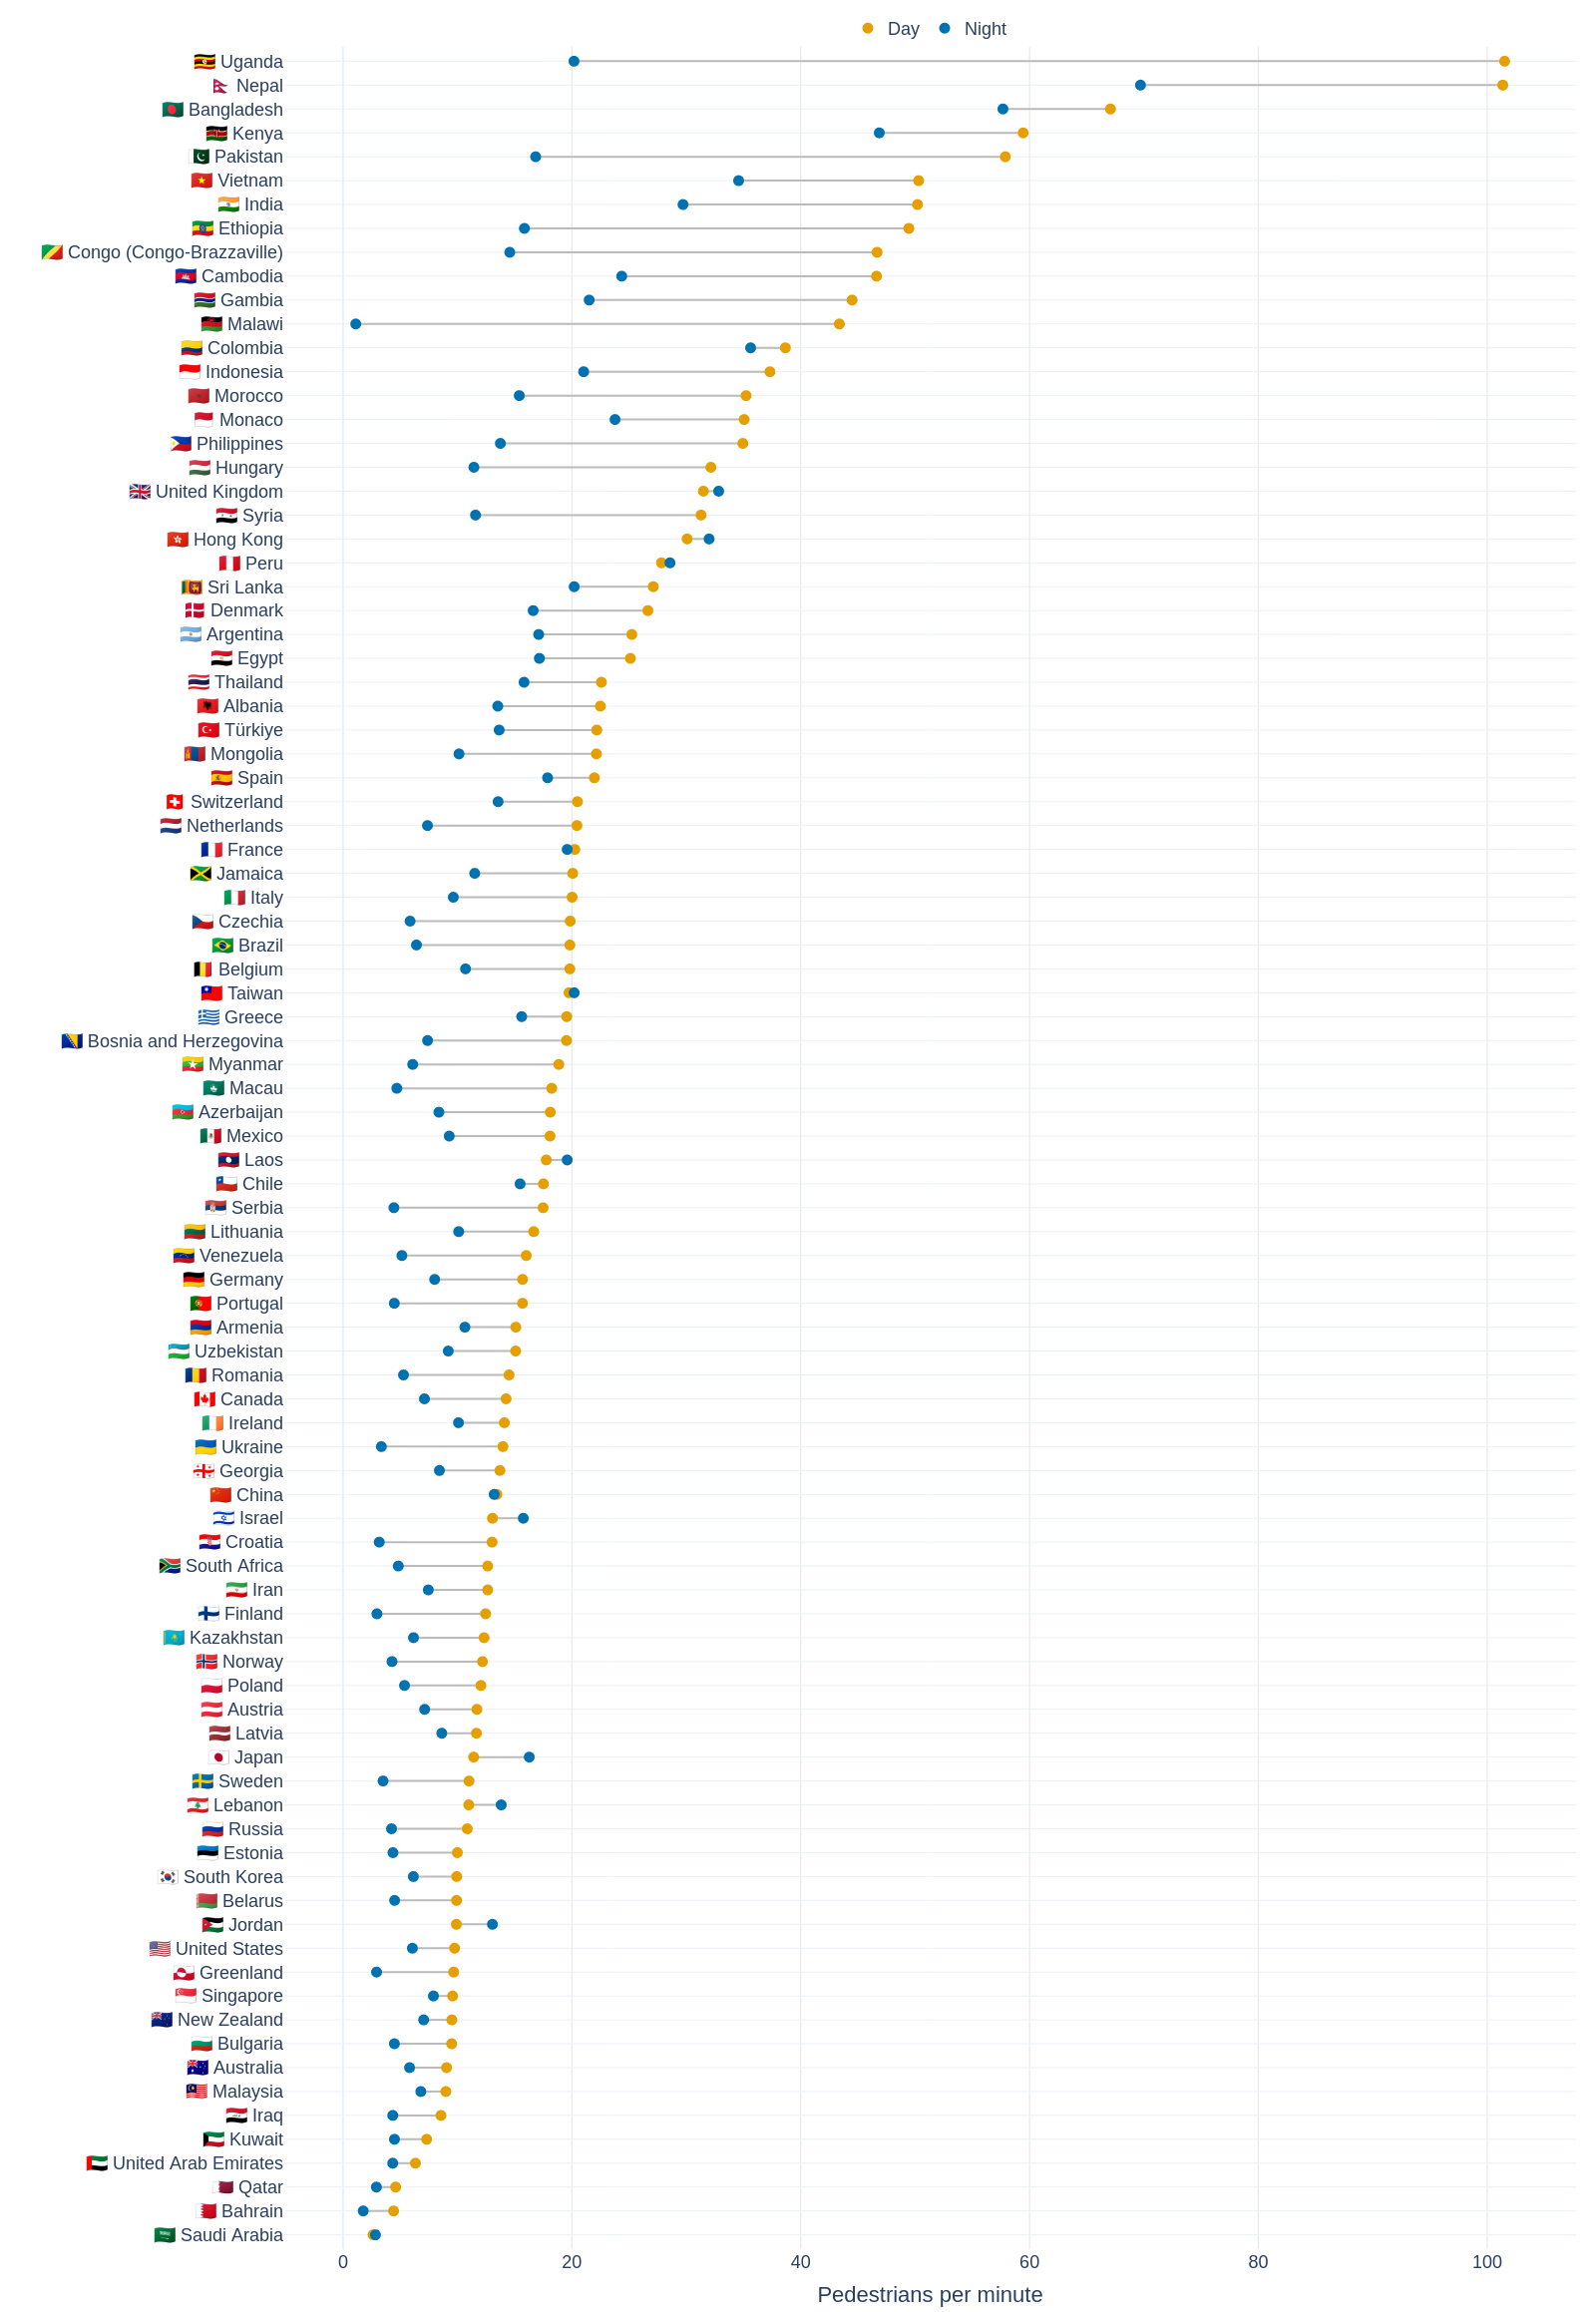
How do pedestrians cross the road in Lagos, Hanoi or Eindhoven? The interactions between future cars and pedestrians should be understandable and safe worldwide, yet most traffic research relies on WEIRD (Western, educated, industrialised, rich, democratic) samples. The internet has become ubiquitous, and YouTube is full of dashcam and walking videos recorded on city streets around the world.

So we built CROWD (City Road Observations With Dashcams), an open dataset of hand-picked day and night urban footage from YouTube, analysed with computer vision to compare the behaviour of road users across countries and cultures. The dataset grows every night.

35661hours of footage
80533videos
10287cities & towns
238countries & territories
Detecting and tracking road users in a dashcam video.

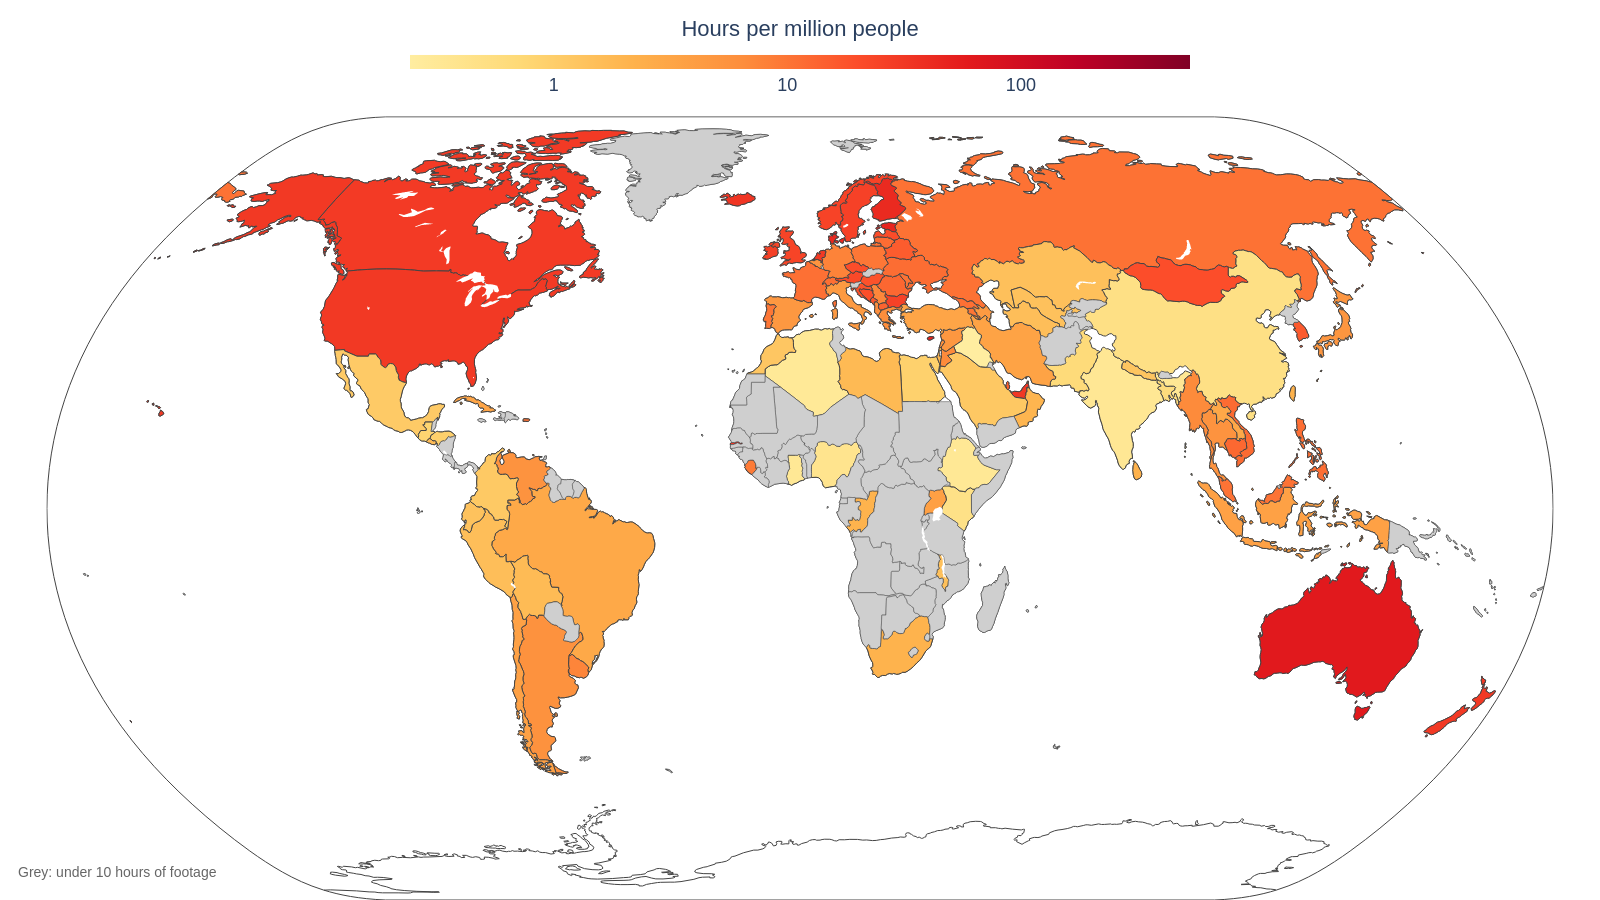
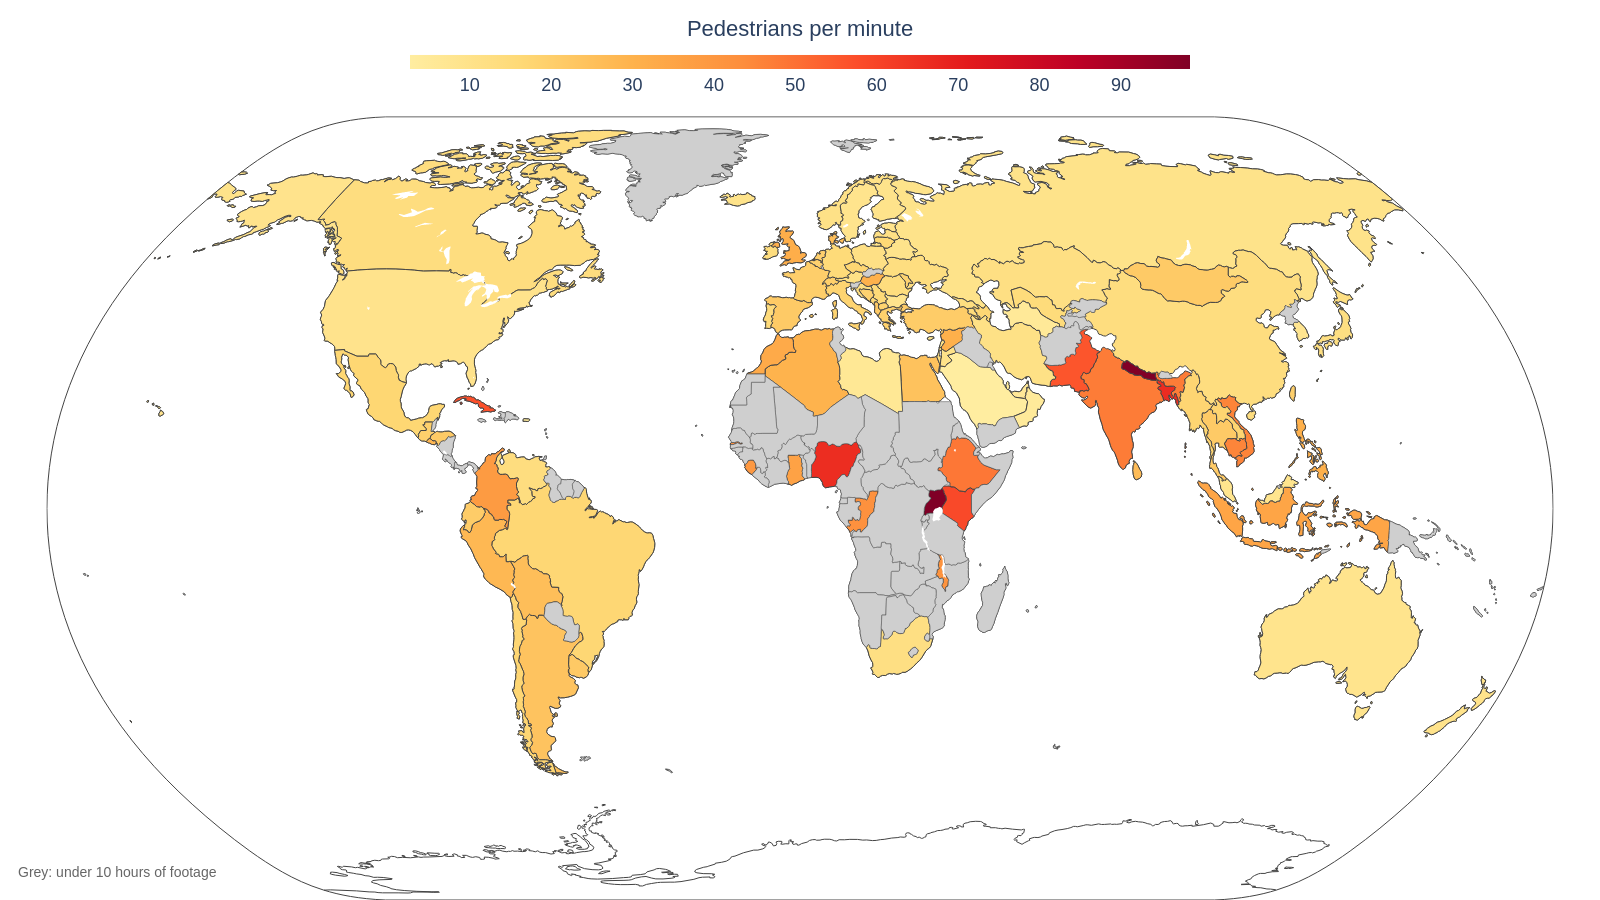
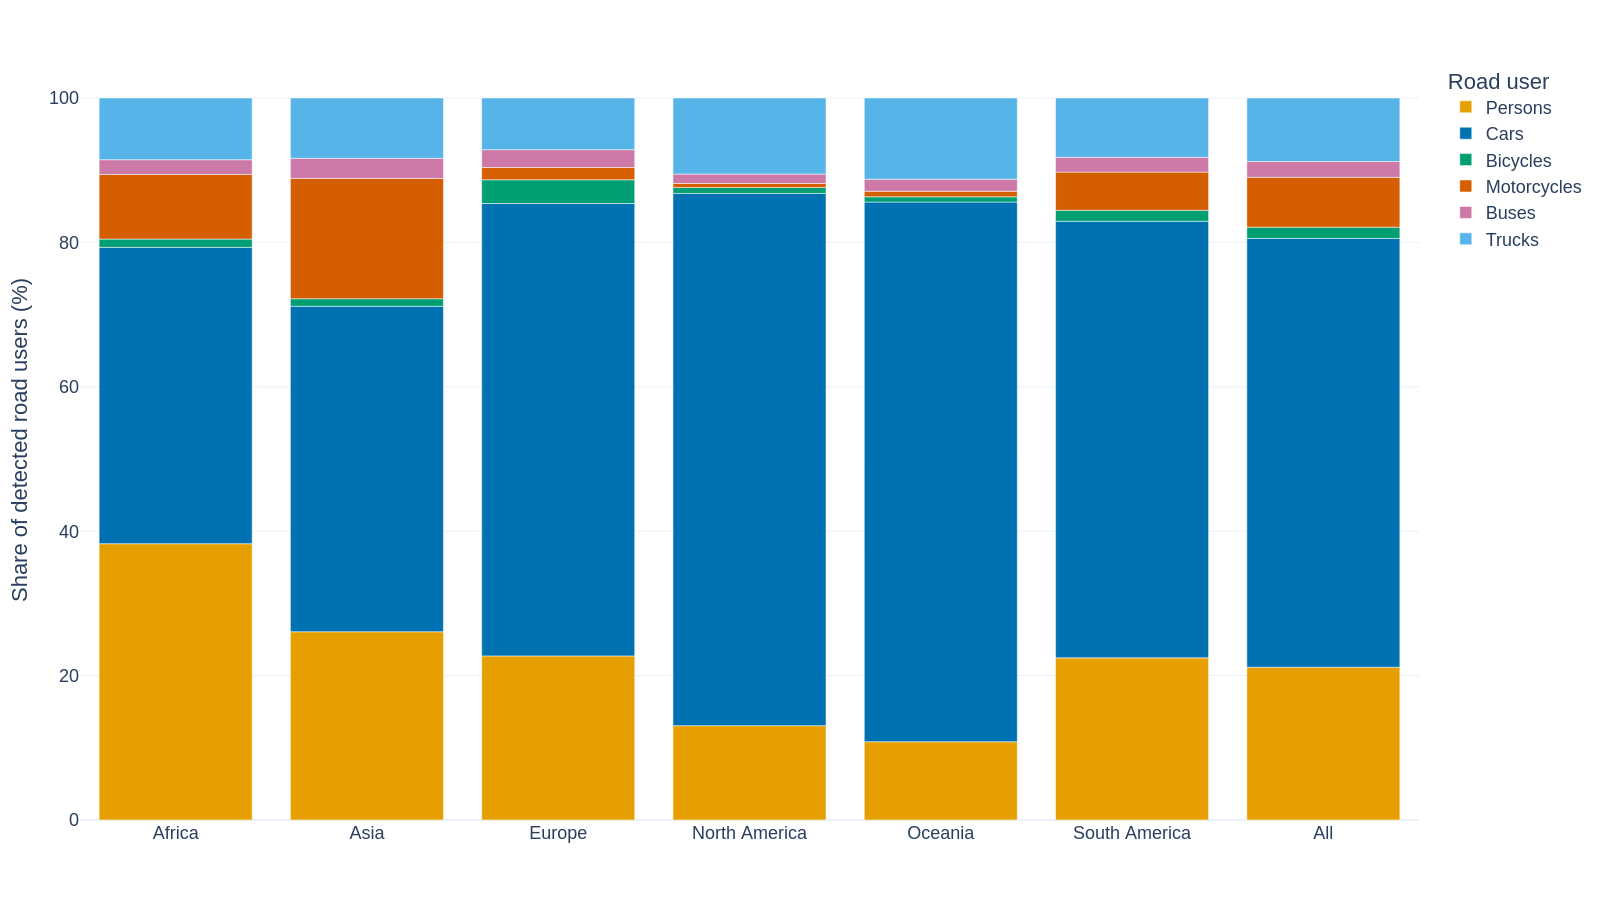
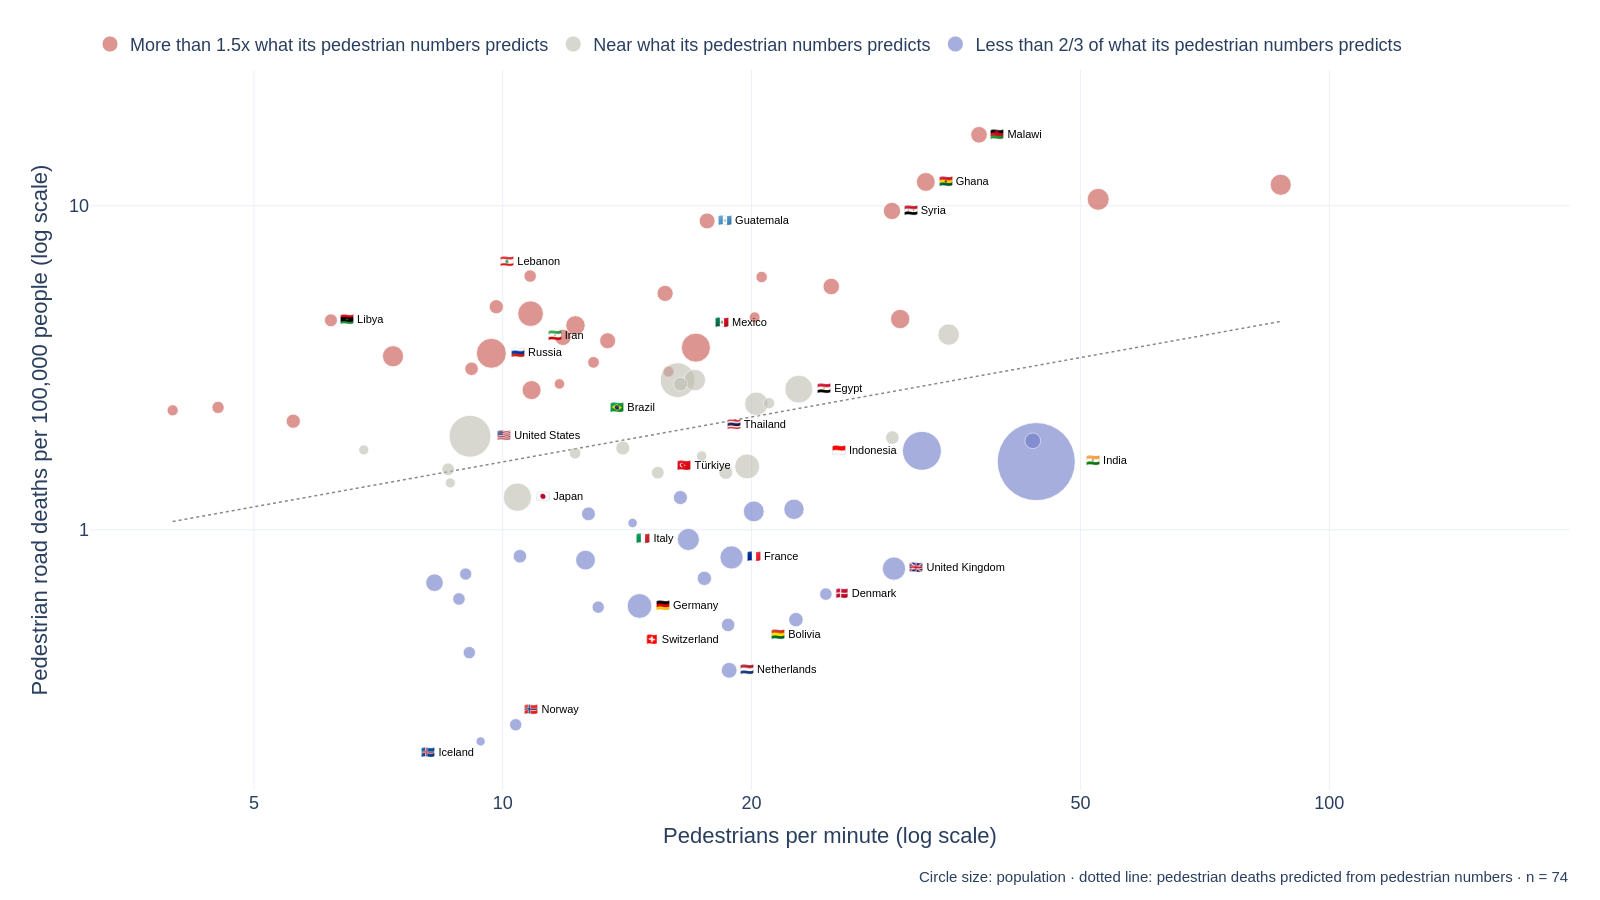
Using YOLO-based detection and tracking, we analysed pedestrian behaviour at the city level (565 cities) and the country level (233 countries and territories). We are now going beyond YOLO, combining detection, multi-object tracking, semantic understanding, depth estimation and 3D scene reasoning, to understand more precisely what happens on the streets of cities on every continent.

Explore the dataset

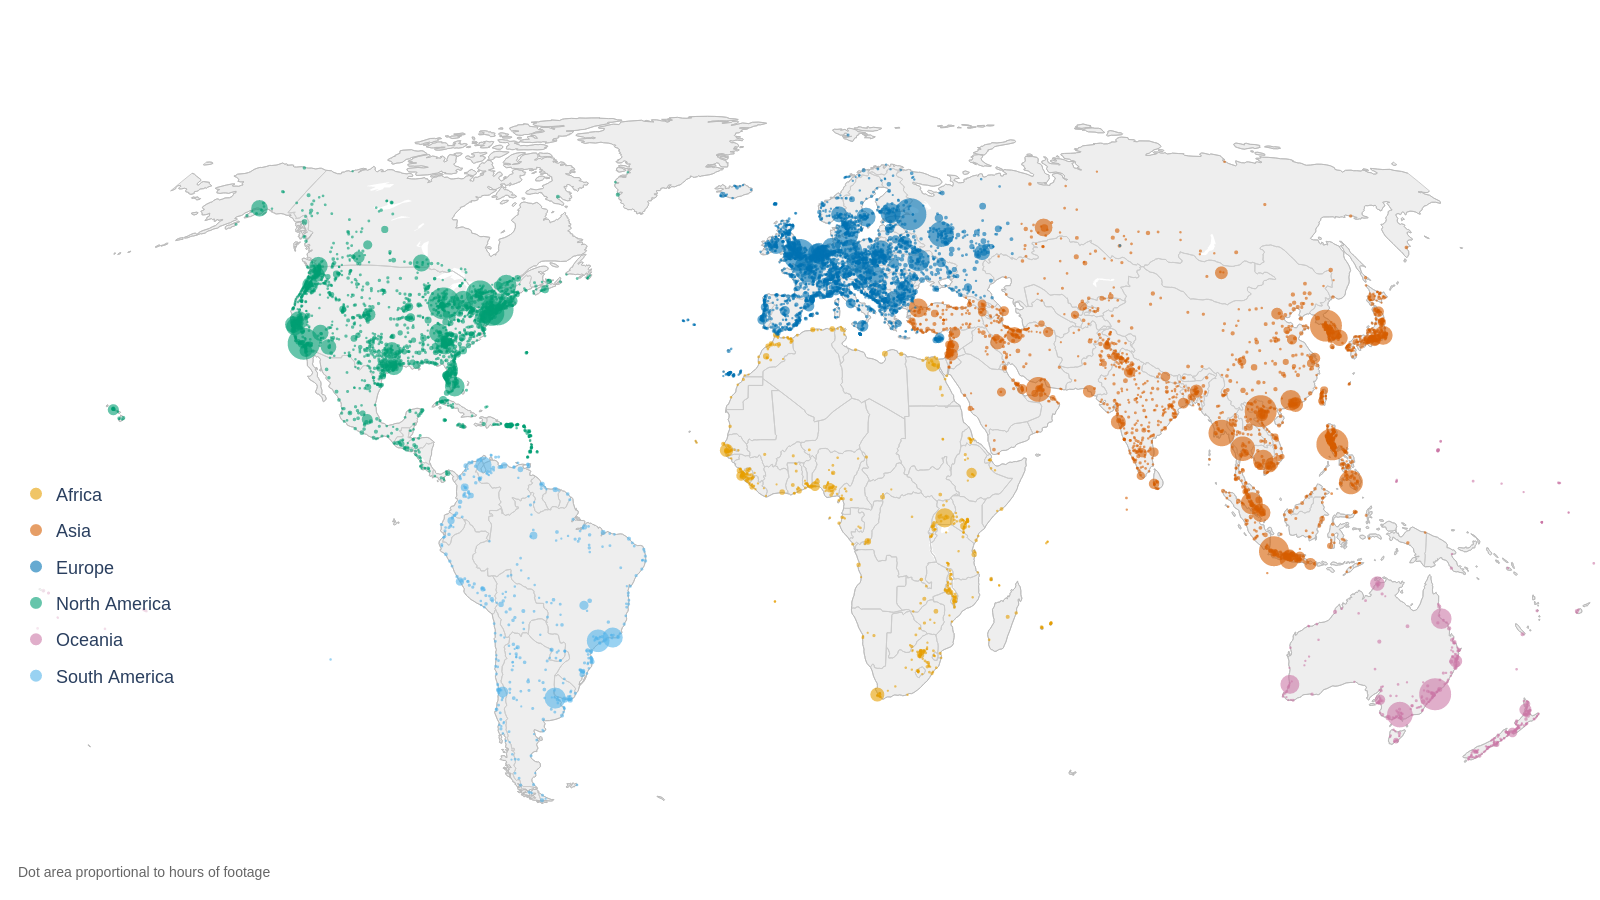
Every town and city in the dataset, sized by its hours of footage.
Every town and city in the dataset, sized by its hours of footage. Open the interactive chart ↗

Is your city in CROWD?

Virtual reality experiments

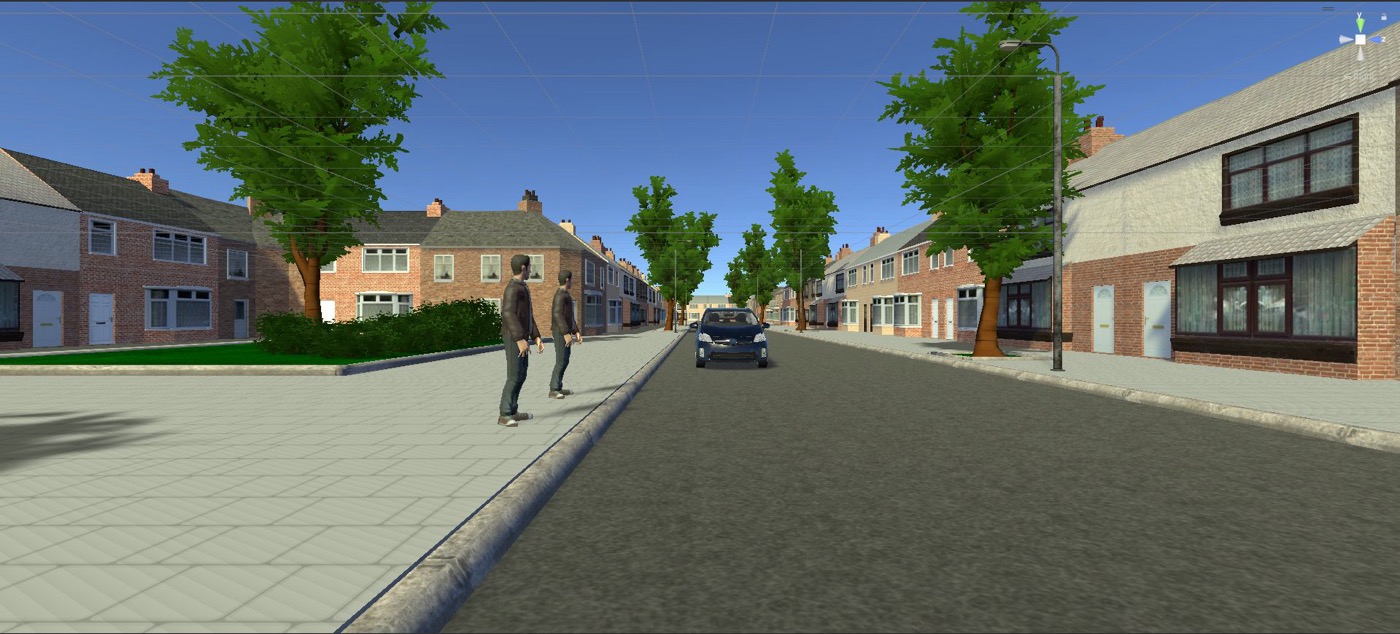
Real roads are not a safe place to test how pedestrians react to an automated vehicle that may or may not stop. In virtual reality, participants stand at the kerb of a realistic street while cars approach, yield or drive past, and we can vary one thing at a time: the vehicle's behaviour, the signals it shows, the sounds it makes and who else is standing nearby.

Participants wear a Meta Quest 3 headset in a street scene built in Unity, and hold a controller trigger whenever they feel it would be unsafe to cross. Recording the trigger and head movements 50 times per second shows exactly when, and for how long, people feel unsafe.

When you are not the only pedestrian

Most studies place a single pedestrian in front of an automated vehicle, but real kerbs are shared. Fifty participants stood next to a virtual pedestrian, 2 to 10 m away, in front of or behind them, while the car yielded or not and showed a light-bar eHMI or nothing.

  • 39–53 percentage points less time judged unsafe when the car yielded: its motion was by far the strongest cue.
  • 9 percentage points less time judged unsafe with the eHMI, but only when the participant was first in the car's path.
  • A companion study with 50 more participants showed that a fixed trial order left these conclusions unchanged, but made ratings drift over the session.

How should a quiet electric car sound?

Electric vehicles are hard to hear, so regulations require them to emit an exterior sound, which adds to urban noise. In 15 VR scenarios, a car passed in front of participants while playing pure, intermittent or complex tones, compared with a diesel engine and tyre noise alone.

  • Participants rated each sound's annoyance, noticeability and informativeness, and used the trigger to show when they would cross.
  • Psychoacoustic metrics predicted annoyance better than conventional sound levels.
  • The results point to EV sounds that are easy to notice without adding noise pollution.

Do we need human participants for human factors research?

The logical next step is to ask whether we even need human participants to conduct (basic) human factors research. Some hypotheses must be tested in a tightly controlled environment with expensive eye trackers. But some research questions might be answered through the "wisdom of humanity up to a certain point in time", which is arguably what a large language model is.

In this study, we used the GPT-4V vision-language model to compare LLM-based assessments of risk with findings from a crowdsourced study with 1,378 participants. Population-level human risk could be predicted with AI with a high degree of accuracy. We also explored how 11 LLMs evaluate external human-machine interfaces (eHMIs) on automated vehicles.

Autonomous ship control with deep RL and maritime expertise

My master's research brings together classic maritime control and modern AI. Autopilots based on PID or PD control and line-of-sight (LOS) guidance have navigated ships safely for decades, and deep reinforcement learning (DRL) promises controllers that adapt and optimise themselves.

The central challenge of DRL for vessels is the amount of training data and computing time it needs. We "fast-track" training by first letting the agent learn from traditional controllers through behavioural cloning, then letting it explore on its own. Validated in simulation and with a scaled model of the benchmark KCS container ship, the DRL agents followed paths effectively, converged faster and stayed safer in strong winds and other challenging conditions.

Read more in Ocean Engineering and the Journal of Marine Engineering & Technology.

A DRL (DQN) controller steering an autonomous ship.

Code & data

I share the code, analysis and data behind my papers, so others can check, reuse and build on them. 26 papers come with open code or data, 13 of them with an open dataset.